System reference
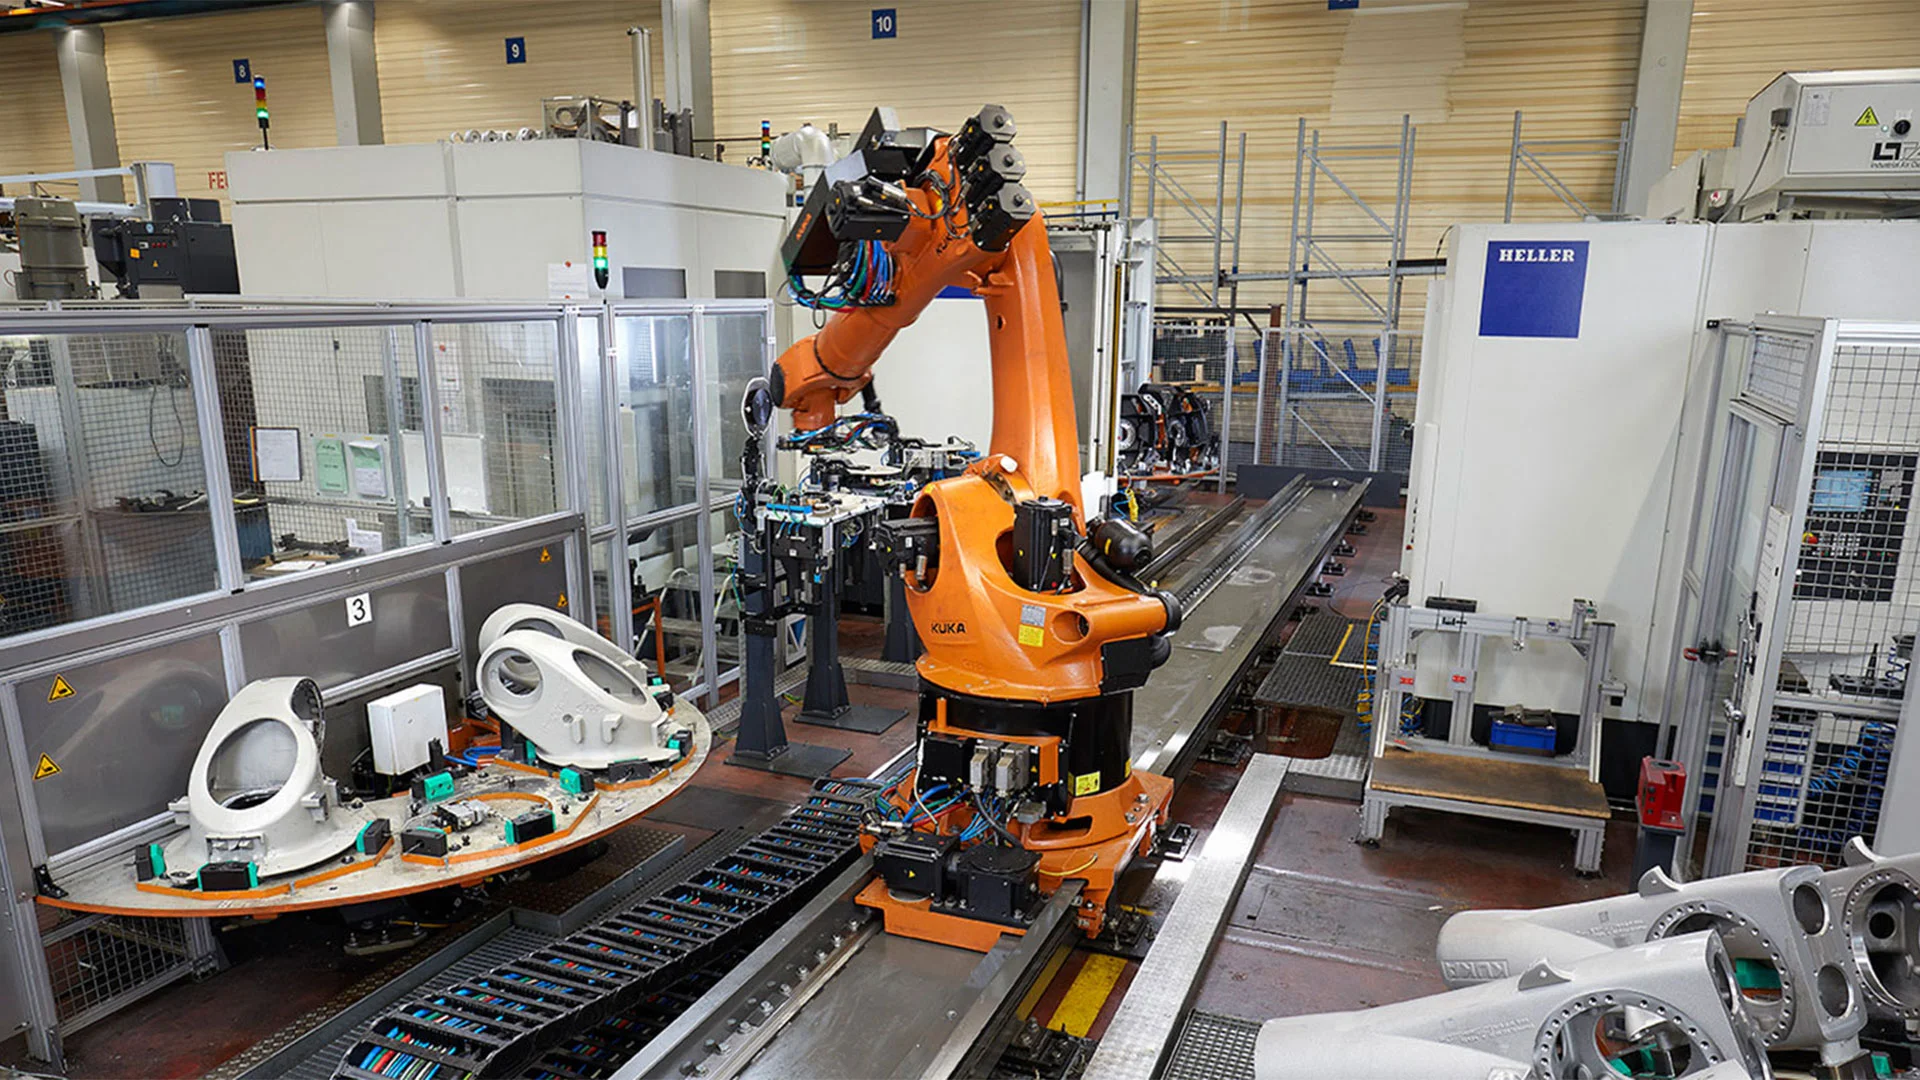
Handling system for robot housing
System solutions | Robotic solutions | Industrial robots
Tool Changers
Series WWR1000
2-Jaw Parallel Grippers
Series GP400

- High gripping force as a result of optimal direction change of driving force into gripping force
2. 2-jaw parallel grippers

- High gripping force as a result of optimal direction change of driving force into gripping force

Challenge
Three machining centers were to be interlinked with a robot. Since the automation was retrofitted, the space requirement and thus the robot size was limited. A very large variety of parts was also to be run on the machines.
Solution
Due to the variety of parts, an automatic gripper change was used. The grippers were designed to be weight-optimized so that a compact robot could be used.
Highlights and technical data
 IP40
 Pneumatic
 External gripping
 Internal gripping
 Position maintenance by means of clamping element
Technical Data
| Drive type | PNEU |
| Max. gripping force | 6600 [N] |
| Gripping concept | FORM |
| Gripping safety device | KLE |
| Max. stroke | 200 [mm] |
| IP class | IP40 |
| System weight | 112 [kg] |
Built-in standard components
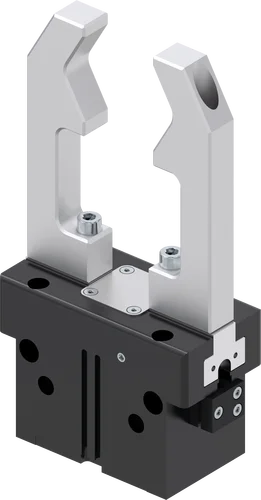
2-Jaw Parallel Grippers
Series GP400
pneumatic
Stroke per jaw
2 mm - 30 mm
Gripping force
85 N - 19275 N
Gripper finger length
50 mm - 300 mm
Maintenance-free cycles max.
10 million
IP class
IP40
Weight
0.076 kg - 17 kg
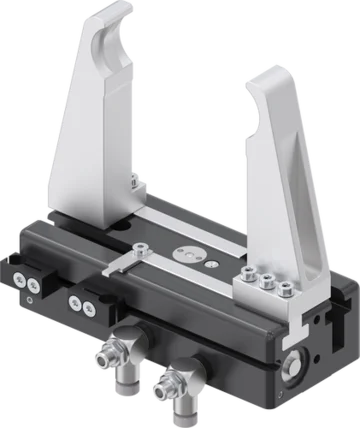
2-Jaw Parallel Grippers with Long Stroke
Series GH6000
pneumatic
Stroke per jaw
20 mm - 200 mm
Gripping force
150 N - 3400 N
Gripper finger length
150 mm - 400 mm
Maintenance-free cycles max.
10 million
IP class
IP40 / IP54
Weight
0.33 kg - 24 kg
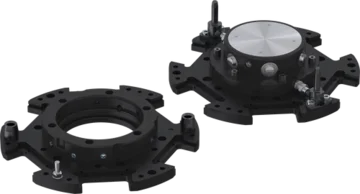
Tool Changers
Series WWR1000
pneumatic
Connecting flange according EN ISO 9409-1
160 / 200
Electrical energy transfer
optional
Locking stroke
1 mm
Weight
5.3 kg - 15 kg